|
Teaya Yang I am a PhD candidate at UC Berkeley advised by Prof. Mark W. Mueller. I am a member of the High Performance Robotics (HiPeR) Lab and affiliated with the Berkeley Artificial Intelligence Research (BAIR) Lab. I received my B.S. degree in Mechanical Engineering from Cornell University in 2022, where I conducted research under the supervision of Prof. Itai Cohen. Email | CV | Google Scholar | LinkedIn |

|
ResearchMy research focuses on perception-driven autonomy for uncrewed aerial vehicles (UAVs), with the goal of enabling reliable operation at scale in complex, GPS-denied environments. Working at the intersection of perception, state estimation, and motion planning, I develop methods that allow UAVs to reason about their environment and navigate using onboard sensing. My current work explores information-theoretic approaches to perception-aware navigation, alongside field robotics applications in agriculture and infrastructure inspection and maintenance. I'm always happy to connect and collaborate. If you're interested in my work, feel free to reach out! |
|
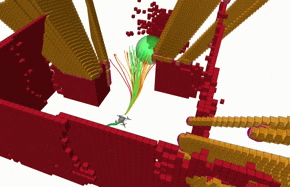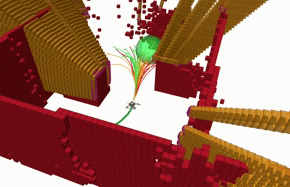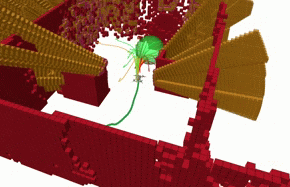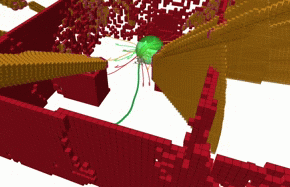
OA-MPPI: Occlusion-Aware Model Predictive Path Integral Control for UAV Flight
Vittorio Palladino, Teaya Yang, Ruiqi Zhang, Mark W. Mueller Preprint, 2026 arXiv | Video An occlusion-aware motion planning framework for avoiding potential collisions with agents hidden behind obstacles. |
|
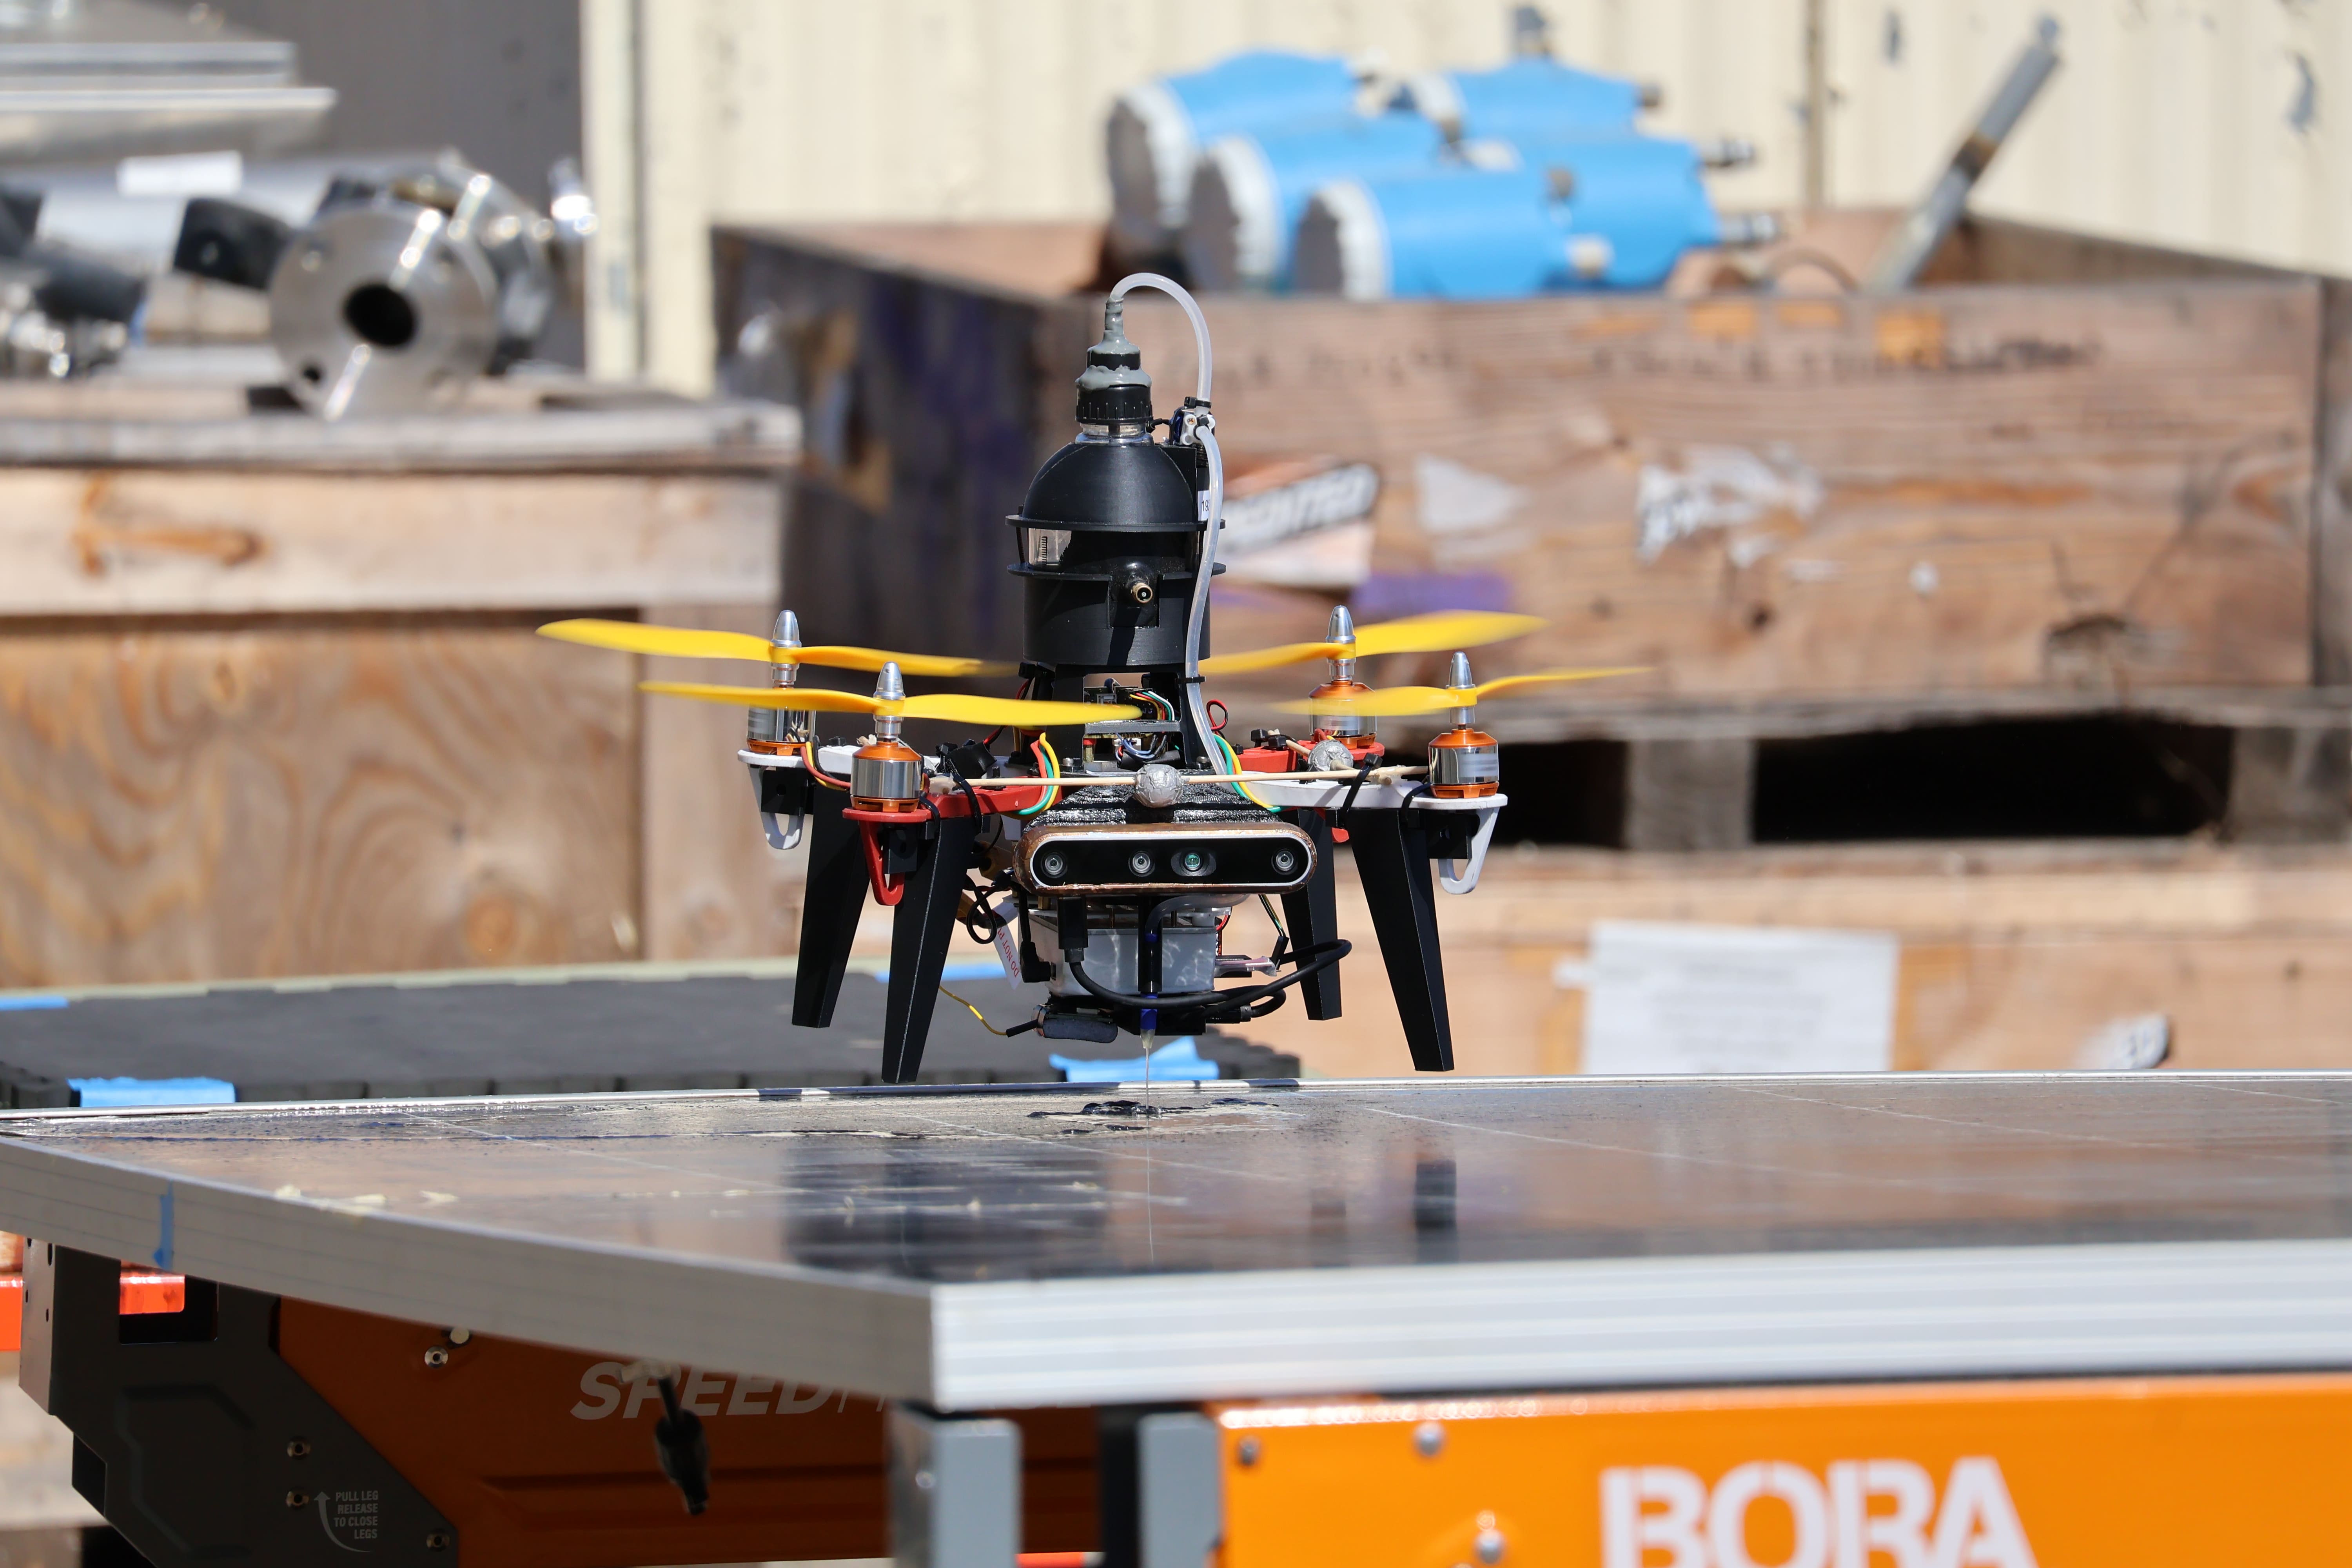
Autonomous Close-Proximity Photovoltaic Panel Coating Using a Quadcopter
Dimitri Jacquemont, Carlo Bosio, Teaya Yang, Ruiqi Zhang, Ozgur Orun, Shuai Li, Reza Alam, Thomas M. Schutzius, Simo A. Makiharju, Mark W. Mueller International Conference on Intelligent Robots and Systems (IROS), 2026 arXiv | Video An autonomous system that applies protective coatings to solar panels using onboard perception and control for close-proximity flight. |

|
Feature-Based Perception-Aware Multi-UAV Trajectory Planning
Teaya Yang, Christian Brommer, Mark W. Mueller American Control Conference (ACC), 2026 Publisher | Poster A multi-UAV trajectory planning framework that incorporates vision-based estimator uncertainty through shared feature alignment and perception-aware rewards. |

|
Towards Safe and Efficient Through-the-Canopy Autonomous Fruit Counting with UAVs
Teaya Yang, Roman Ibrahimov, Mark W. Mueller International Conference on Robotics and Automation (ICRA), 2025 Publisher | arXiv | Video | Poster An autonomous system for fruit counting through RGB images with a focus on through-the-canopy data collection. |

|
AgriNav: UAV Simulator for Vision-based Navigation in Agricultural Environments
Teaya Yang, Mark W. Mueller IFAC Conference on Sensing, Control and Automation Technologies for Agriculture (AGRICONTROL), 2025 Publisher | Code A simulator for UAV navigation in agricultural environments with built-in support for visual-inertial odometry. |

|
A Tactile Feedback Approach to Path Recovery after High-Speed Impacts for Collision-Resilient Drones
Anton Bredenbeck, Teaya Yang, Salua Hamaza, Mark W. Mueller Drones, 2025 Publisher | Video A collision-aware path recovery method for high-speed tensegrity drones using binary contact sensing and vector-field-based navigation. |

|
Bifurcation Instructed Design of Multistate Machines
Teaya Yang, David Hathcock, Yuchao Chen, Paul L. McEuen, James P. Sethna, Itai Cohen, Itay Griniasty Proceedings of the National Academy of Sciences (PNAS), 2023 Publisher | arXiv A novel design paradigm for multistate machines where state transitions are organized by bifurcations of equilibria. |
Service
Teaching
- Graduate Student Instructor – ME231B: Experiential Advanced Control Design II (Spring 2024, Spring 2025; ~20 hrs/week)
- Discussion Cluster Workshop Leader – UC Berkeley Teaching Conference for First-Time GSIs (Fall 2026; 3.5-hour workshop)
- Capstone Project Advisor – UC Berkeley Master of Engineering (M.Eng.) Program (Fall 2024–Spring 2027)
Academic Service
- Organizer, Bay Area Robotics Symposium (BARS) 2023
- Journal Reviewer: Transactions on Mechatronics (T-Mech), Transactions on Automation Science and Engineering (T-ASE), Transactions on Control Systems Technology (T-CST), Robotics and Automation Letters (RA-L), Open Journal of Control Systems (OJ-CSYS), Journal of Aerospace Information Systems (JAIS)
- Conference Reviewer: International Conference on Intelligent Robots and Systems (IROS), American Control Conference (ACC), IFAC Conference on Sensing, Control and Automation Technologies for Agriculture (AGRICONTROL)
Outreach
- Mentored middle school students through the Be a Scientist Program at MLK Middle School (2026)
- Organized lab visits and activities for high school students through the Berkeley MET summer program (2024, 2025, 2026)
- Delivered a STEM outreach talk and showcase at EBI Middle School (2023)
- Mentored a summer undergraduate researcher through the SUPERB program at Berkeley (2023)
|
This website is adapted from Jon Barron. Last updated: Sep, 2026 |